Bulk High Speed Egg Robotic Packaging Machine
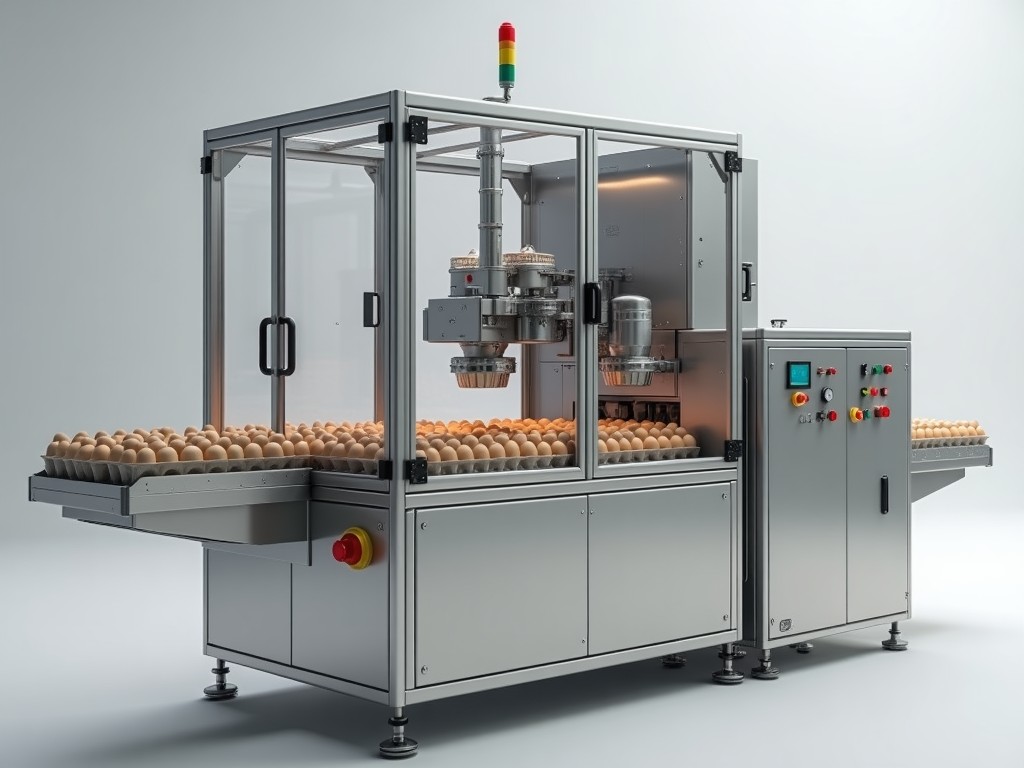
Bulk High Speed Egg Robotic Packaging Machine
This equipment integrates high‑speed robotic arms with vision‑guided handling to load, orient, and place eggs into cartons, trays, or bulk containers at rates suitable for large‑scale processing facilities. The design focuses on minimizing mechanical stress on the shell while maintaining precise positional accuracy for downstream sealing or labeling operations.
Overview
The machine consists of a stainless‑steel frame, a series of delta‑type or articulated robotic arms, a conveyor infeed that singulates eggs, and a programmable logic controller (PLC) coordinating motion, vision inspection, and ejection of defective units. Each arm operates within a defined work envelope to avoid interference, allowing simultaneous picking and placing cycles.
Working Principle
Eggs arrive on a vibrating feeder that aligns them with their long axis parallel to the conveyor. A 3D vision system identifies orientation, detects cracks, and communicates the required grip angle to the robot controller. The robotic arm then extends, uses a soft‑grip end effector equipped with silicone suction cups or compliant fingers, lifts the egg, rotates it to the desired orientation, and places it into the pocket of a moving carton or tray.
Cycle timing is governed by the slowest of three stages: vision processing (typically 120 ms), arm travel (dependent on distance and speed settings), and placement stabilization (to prevent bounce). By overlapping vision processing with arm movement of the next egg, the system achieves a continuous flow rather than a stepwise start‑stop motion.
Technical Specifications
| Parameter | Typical Value | Unit |
|---|---|---|
| Throughput (variable with egg size) | 20,000 – 40,000 | eggs/hour |
| Number of robotic arms | 2 – 4 | units |
| Cycle time per egg | 0.6 – 1.2 | seconds |
| Position repeatability | ±0.2 | mm |
| Power consumption | 3.5 – 5.0 | kW |
| Footprint (L × W × H) | 2.2 × 1.0 × 2.0 | m |
| Control system | PLC with HMI (touchscreen) | – |
Key Features
- Soft‑grip end effector designed to apply less than 0.5 N force, reducing shell fracture risk.
- Modular arm configuration allows scaling throughput by adding or removing units without redesigning the frame.
- Integrated vision inspection rejects misshapen or cracked eggs at >98 % detection rate before packaging.
- Quick‑change tooling accommodates carton sizes from 6‑egg packs to 30‑egg flats and bulk trays.
- Energy‑efficient servo drives with regenerative braking lower operating cost during idle periods.
Applications
In large egg‑processing plants, the machine replaces manual loading or slower mechanical loaders, addressing two critical production concerns: labor intensity and product integrity. Manual handling often introduces variability in orientation and increases the chance of micro‑cracks, which can lead to spoilage during storage. By automating the pick‑and‑place operation with vision feedback, each egg is positioned consistently, reducing downstream sealing failures and improving pack line efficiency. The equipment is also suited for downstream processes such as laser coding or weight checking, where precise egg placement is essential for accurate reading.
Customization Options
- End effector types: vacuum suction with silicone lips, compliant finger grippers, or hybrid designs for specialty products such as quail or duck eggs.
- Conveyor speed range adjustable from 0.1 m/s to 1.5 m/s to match upstream singulator rates.
- Housing materials: 304 stainless steel for standard wash‑down, 316L for high‑salinity or chemical‑rich environments.
- Software add‑ons: data logging for traceability, remote diagnostics via OPC UA, and integration with MES systems.
- Safety upgrades: light curtains, safety‑rated torque limiting, and emergency stop zones configurable per site risk assessment.
Quality Assurance
Each unit undergoes a factory acceptance test that includes cycle‑time verification at maximum rated throughput, repeatability measurement using a laser interferometer, and vision system validation against a known set of defect samples. The mechanical structure is checked for weld integrity and surface finish to meet food‑grade hygiene standards. Documentation of test results, material certificates, and CE conformity declarations is provided with the shipment. Optional on‑site performance qualification can be arranged to confirm that the machine meets specific line speed and yield targets before final acceptance.
Request More Information
To discuss how this equipment can be adapted to your facility’s layout, egg size range, or packaging format, please use the links below to contact our technical team.
Request a quote and project consultation
Learn about customization options for end effectors and conveyors
Review quality assurance documentation and test procedures



